2016年9月22日 星期四

How to build Point Clouds from RealSense driver in Linux

Overview  

    This article will illustrate how to feed the raw data from RealSense driver (in Linux) to the Point Cloud Library.

Background

    One can apply the RealSense SDK to perform some fascinating features in their application with ease.  Unfortunately, if you develop your APP in Linux, there's no such good things (at least when I wrote this article).  One way to go further is to transport the raw data from RealSense driver to OpenCV or Point Cloud Library (PCL). There're some hints for the former such as here (see Lesly Z.  Thu, 08/11/2016 - 03:29), while the tutorial of the latter can't be found easily and is what this article aimed for.

Solution

   There's an example shipped with the RealSense driver that teach you how to build PointCloud from libRealSense.  However, if you want to apply the PointCloudLibrary utilities to it, you should further convert it to the PCL format.
    In this article, I wrap such conversion and the device data extraction in a class called RealSenseController, which can be used as follows:
RealSenseController realSenseDevice;

while(true)
{
                realSenseDevice.Update();
                realSenseDevice.CalculatePointCloud();

                pcl::PointCloud<pointxyzrgb>::Ptr currentPointCloud = realSenseDevice.GetPointCloud();
                DoSomeThing(currentPointCloud);
}

in which the RealSenseController::Update() will update the current depth and color image from the device, and RealSenseControllers::CalculatePointCloud() will compute the PointCloud base on such depth and color image.

This class is defined as below:
class RealSenseController
{
        public:
                void Update();
                const cv::Mat& GetColorImage() const;
                const cv::Mat& GetDepthImage() const;
                const pcl::PointCloud<pointxyzrgb>::Ptr GetPointCloud() const;
                void CalculatePointCloud();


                RealSenseController();

        private:
                rs::context deviceList;
                rs::device* cameraDevice;
                rs::intrinsics depthIntrinsicTransform;
                rs::extrinsics depthToColorTransform;
                rs::intrinsics colorIntrinsicTransform;

                cv::Mat currentColorImage;
                cv::Mat currentDepthImage;

                pcl::PointCloud<pointxyzrgb>::Ptr pointCloud;

                void initializeDevicesController();
                void initializeCameraDevice();
                void enableALlVedioStreams();
                void initializeDeviceTransforms();
                void updateColorImage();
                void updateDepthImage();
                rs::float3 getDepthPosition3D(size_t rowIndex_, size_t columnIndex_);
                cv::Vec3b getColorRelateToDepthPosition(rs::float3 depthPosition3D_) const;
                bool isColorPositionValid(rs::int2 colorPosition2D_) const;
                rs::int2 convertToNormalPixelFormat(const rs::float2& colorPosition2Dfloat) const;
                PointXYZRGB createPointXYZRGB(rs::float3 position3D_, cv::Vec3b pointColorBGR_) const;
                float getDepthValueInMeters(size_t rowIndex_, size_t columnIndex_) const;


};


Following is the initialization of the RealSenseController:
RealSenseController::RealSenseController()
 : deviceList(),
   cameraDevice(),
   depthIntrinsicTransform(),
   depthToColorTransform(),
   colorIntrinsicTransform(),
   currentColorImage(),
   currentDepthImage(),
   pointCloud(new pcl::PointCloud<pointxyzrgb>() )
{
        this->initializeDevicesControlCenter();
        this->initializeCameraDevice();
        this->enableALlVedioStreams();
        this->cameraDevice->start();
        this->initializeDeviceTransforms();
}

void RealSenseController::initializeDevicesController()
{
        int numberOfRealSenseDevicesConnected = this->deviceList.get_device_count();

        if (numberOfRealSenseDevicesConnected == 0)
                throw RealSenseNotConnectedException();
}
void RealSenseController::initializeCameraDevice()
{
        this->cameraDevice = this->deviceList.get_device(0);
}
void RealSenseController::enableALlVedioStreams()
{
        this->cameraDevice->enable_stream(rs::stream::color, rs::preset::best_quality);
        this->cameraDevice->enable_stream(rs::stream::depth, rs::preset::best_quality);
}
void RealSenseController::initializeDeviceTransforms()
{
        this->depthIntrinsicTransform = this->cameraDevice->get_stream_intrinsics(rs::stream::depth);
        this->depthToColorTransform  = this->cameraDevice->get_extrinsics(rs::stream::depth, rs::stream::color);
        this->colorIntrinsicTransform = this->cameraDevice->get_stream_intrinsics(rs::stream::color);
}


      The following function will update the color and depth image from the device and store it to the cv::Mat in OpenCV, since the format of the device raw data and cv::Mat are similar and can be expected to convert efficiently.
void RealSenseController::Update()
{
        try
        {
                this->cameraDevice->wait_for_frames();
        }
        catch(...)
        {
                std::cerr<<"Device->wait_for_frames() times out\n";
        }
        this->updateColorImage();
        this->updateDepthImage();
}
void RealSenseController::updateColorImage()
{
        const void* deviceColorData = this->cameraDevice->get_frame_data(rs::stream::color);
        cv::Mat colorTemp = cv::Mat( this->colorIntrinsicTransform.height, this->colorIntrinsicTransform.width, CV_8UC3, const_cast<void*>(deviceColorData) );
        cv::cvtColor(colorTemp, this->currentColorImage, CV_RGB2BGR);
}
void RealSenseController::updateDepthImage()
{
        const void* deviceDepthData = this->cameraDevice->get_frame_data(rs::stream::depth);
        this->currentDepthImage = cv::Mat(this->depthIntrinsicTransform.height, this->depthIntrinsicTransform.width, CV_16UC1, const_cast<void*>(deviceDepthData) );
}


Note:  1. One should call rs::device::wait_for_frames() before getting any data from device.
               Moreover, that function might throw exception if device times out (no data received from
               device over some period).  In this case, I just ignore it and keep trying to get data.  Most of
               the time, the device will recover and continue to send data.
           2. The argument order of the cv::Mat constructor is column number first then comes the row
                number.
           3. The type of device raw data is "const void*", one should do const_cast<>() before feed it
                into cv::Mat.
           4.  The format of the color data is RGB, and should be changed to BGR which is widely
                adopted by OpenCV.

    Following code block perform the transformation from 2D depth and color image to form a PointCloud:
void RealSenseController::CalculatePointCloud()
{
        if ( (not this->currentColorImage.empty())and(not this->currentDepthImage.empty() ) )
        {
                this->pointCloud->clear();

                for (size_t i=0; i < (size_t)this->currentColorImage.cols; ++i)
                {
                        for (size_t j=0; j <  (size_t)this->currentColorImage.rows; ++j)
                        {
                                rs::float3 depthPosition3D = getDepthPosition3D(i, j);
                                try
                                {
                                        cv::Vec3b colorRelativeToDepth = getColorRelateToDepthPosition(depthPosition3D);
                                        PointXYZRGB currentPoint = createPointXYZRGB(depthPosition3D, colorRelativeToDepth);

                                        this->pointCloud->push_back( currentPoint );
                                }
                                catch(const InvalidPointException& error)
                                {
                                        // Neglect the NAN point
                                        continue;
                                }
                        }
                }
        }
        else
        {
                std::cerr<<"Color or Depth Image is empty, ignore the calculation this frame.\n";
        }
}
rs::float3 RealSenseController::getDepthPosition3D(size_t rowIndex_, size_t columnIndex_)
{
        rs::float2 depthPosition2D = { (float)columnIndex_, (float)rowIndex_ };
        float depthValue = getDepthValueInMeters(rowIndex_, columnIndex_);
        return this->depthIntrinsicTransform.deproject(depthPosition2D, depthValue);
}

///
/// This function will throw InvalidPointException, if the Point is invalid (such as there's no match from depth to color pixel.
///
cv::Vec3b RealSenseController::getColorRelateToDepthPosition(rs::float3 depthPosition3D_) const
{
        rs::float3 colorPosition3D_RelativeTo_depthPosition = this->depthToColorTransform.transform(depthPosition3D_);

        rs::float2 colorPosition2Dfloat = this->colorIntrinsicTransform.project(colorPosition3D_RelativeTo_depthPosition);
        rs::int2 colorPosition2Dint = this->convertToNormalPixelFormat(colorPosition2Dfloat);

        if ( this->isColorPositionValid(colorPosition2Dint) )
        {
                return this->currentColorImage.at<cv::vec3b>( colorPosition2Dint.y, colorPosition2Dint.x );
        }
        else
        {
                /*
                   The current Point do not have meaning, and should be ignored.
                */
                throw InvalidPointException();
        }
}
bool RealSenseController::isColorPositionValid(rs::int2 colorPosition2D_) const
{
        return ( (colorPosition2D_.x >= 0)and(colorPosition2D_.y >= 0)
                  and(colorPosition2D_.x < this->colorIntrinsicTransform.width)
                  and(colorPosition2D_.y < this->colorIntrinsicTransform.height) );
}

rs::int2 RealSenseController::convertToNormalPixelFormat(const rs::float2& colorPosition2Dfloat) const
{
        rs::int2 colorPosition2Dint;
        colorPosition2Dint.x = (int)std::round(colorPosition2Dfloat.x);
        colorPosition2Dint.y = (int)std::round(colorPosition2Dfloat.y);
        return colorPosition2Dint;
}
PointXYZRGB RealSenseController::createPointXYZRGB(rs::float3 position3D_, cv::Vec3b pointColorBGR_) const
{
        PointXYZRGB tempPoint;
        tempPoint.x = position3D_.x; tempPoint.y = position3D_.y; tempPoint.z = position3D_.z;
        tempPoint.r = pointColorBGR_[2]; tempPoint.g = pointColorBGR_[1]; tempPoint.b = pointColorBGR_[0];

        return tempPoint;
}
float RealSenseController::getDepthValueInMeters(size_t rowIndex_, size_t columnIndex_) const
{
        float depthScale = this->cameraDevice->get_depth_scale();
        size_t MAX_ROW_INDEX = (size_t)this->currentDepthImage.rows;
        size_t MAX_COLUMN_INDEX = (size_t)this->currentDepthImage.cols;
        if ( ( rowIndex_ < MAX_ROW_INDEX )and(columnIndex_ < MAX_COLUMN_INDEX) )
        {
                return (float)this->currentDepthImage.at(rowIndex_, columnIndex_) * depthScale;
        }
        else
        {
                return 0.0f;
        }
}


      The procedure of building PointCloud can be briefly summarized as follows:  1. Convert the 2D position in depth image to 3D depth position.  2. Transform such 3D depth position to the 3D position in the color coordinate.  3. Transform that position into 2D position in the color image, and get the color relative to the position.  4. Now, you have the 3D position and its color. The PointXYZRGB can be built from that.

Note:  1. For convenience, I define a simple structure that mimics the rs::float2 to store the 2D
               position of the color image:
namespace rs
{
        struct int2 { int x, y; };
};

          2. x is column, y is row.
          3. There might be some depth points that do not have their counterparts in the color image. At
              this circumstance, the  example of libRealSense seems to artificially assign it as white.
              However, this will result in too many invalid points near the origin (in my case, the final
              point cloud has 307K points while there're 279K points near the origin and has its color
              been artificially assigned as white).  It will be a disaster if you want to calculate the normals
              of that cloud (the calculation time will be at least 10 minutes).  The similar issues have been
              discussed here.  Therefore, I neglect such invalid points by throwing an
              InvalidPointException which will be caught and ignored by the
              RealSenseController::CalculatePointCloud() and continue the loop.

          3. Finally, you might want to remove the outliers.
              (a) The calculated point cloud (with points 38.2K):
          

              (b) The above point cloud with its outliers removed (with points: 37.9K):
         

2016年5月30日 星期一

Task System (Thread Pool)

Overview

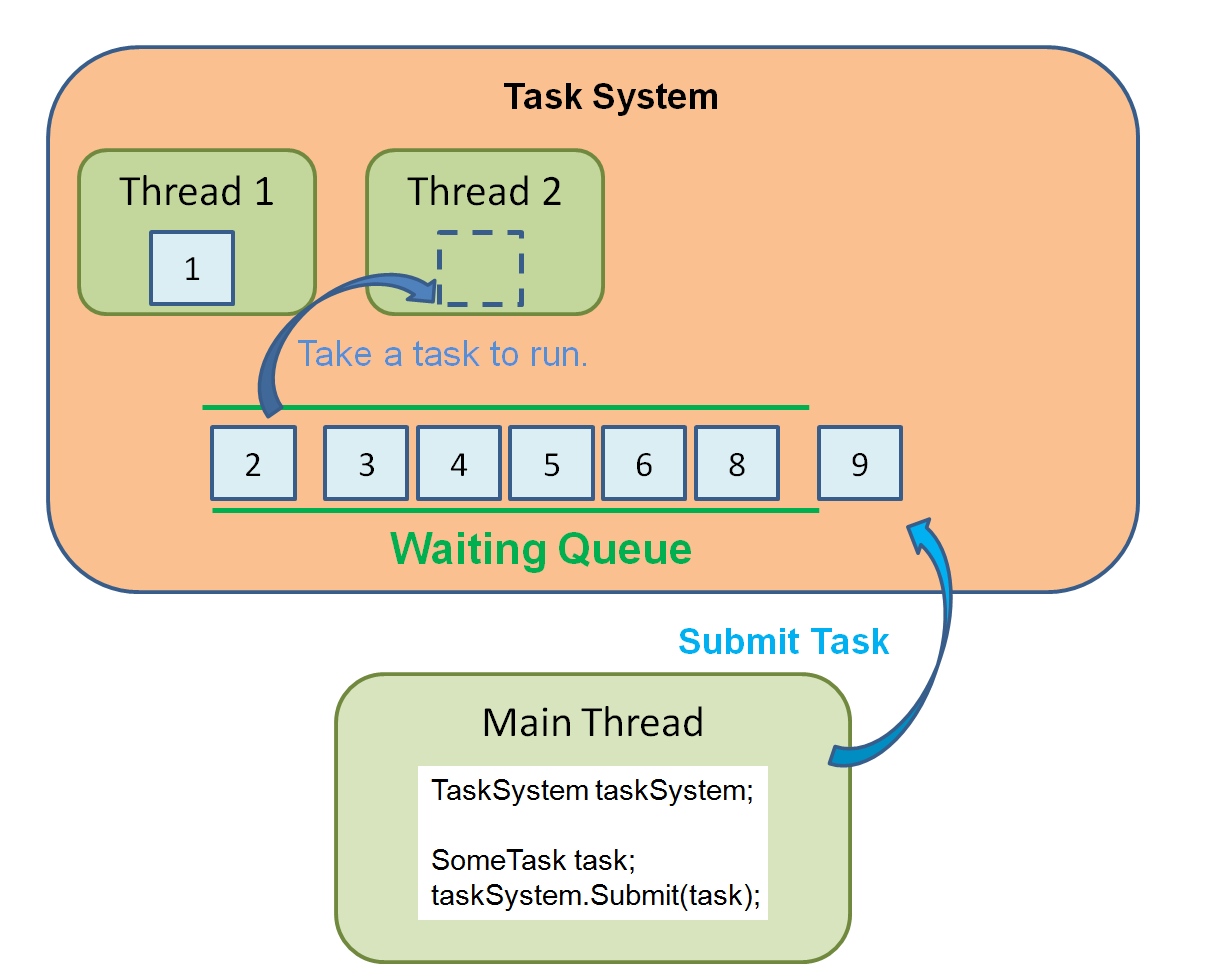
    This article is trying to implement a Task System by using C++11. A TaskSystem will create threads (at its initialization) and process tasks in parallel (see following figure). Each task can be defined and customized by the user.


Motivation

    After reading the "C++ Concurrency In Action", I want to do some exercise. Therefore, that's what this article about: Design and implement a Task System. Furthermore, I have seen an article that discussed about the difficulty to implement Task-Based Parallelism in C++. Therefore, this is what I temp to do here: to give an alternative way to approach the Task System in C++11.

Introduction

   As mentioned by Anthony Williams in his "C++ Concurrency In Action", there're  several circumstances that you might want to apply multi-threads:

1. Each thread perform different work: For example, you might want to use one thread for GUI, another for controlling the inner data so that the GUI can respond to user quickly. This might be the best situation to use threads.

2. Each thread do the same job but process different data: You might divide data into several chunks and submit each chunk to different threads. In this case, how do you split the data and how many threads is created (usually the same number as your processors) harshly effect the performance.

Task System

   The second case is what this article aim for. In that case, you might want to create threads as many as your processors at the beginning (since the creation of thread takes time). And then you can submit jobs (tasks) to those threads. The thread then processes your task and return its result in some way. This is what I call the Task System here (also called thread pool in "C++ Concurrency In Action").
   However, Bartosz Milewski have mentioned in this article that since the std::mutex as well as the thread_local keyword is Thread-Based instead of Task-Based, it has a potential difficulty to implement such Task System.

   In this article, I'd try to implement a simple Task System under two limitations:

1. The task will not migrate from one thread to another.

2. Once a task have been taken by one thread and is being processed, it will not be interrupted or be 'Context Switched' till the end of the task.

And its usage will look like follows (all of the code in this article should be compiled with C++11):
        TaskSystem taskSystem;
        taskSystem.Start();

        SomeTask task;
        std::future<ResultType> resultHolder = task.GetResult();
        taskSystem.Submit( std::make_shared(std::move(task)) );

        ResultType result = std::move(resultHolder.get());

    Here, the TaskSystem is created at the first line, then calling the TaskSystem::Start() will create threads (which will run the user defined task when you submit one). Then I create a Task (which should be inherited from TaskInterface), and get std::future from TaskInterface::GetResult(). Note that std::future is like a bridge between current thread and the work thread. You can hold it which will return the result when you call std::future::get(). At that time, the current thread will wait until the work thread finishes its task. Also note that the task is wrapped by the std::shared_ptr before it has been submitted so that the Task can be  deleted properly.
    The TaskInterface that every Task should inherit is shown as follows:
        template<typename Returntype>
        class TaskInterface
        {
                public:
                        virtual void Run(void) = 0;

                        virtual std::future<Returntype> GetResult(void) = 0;

                        virtual void Interrupt(void) = 0;

                        virtual ~TaskInterface() {};
        };

    The user should define what his Task should do by overriding the function TaskInterface::Run(). The return value is wrapped by std::future which can be obtained by calling TaskInterface::GetResult(). If you want to stop all tasks that have been submited to TaskSystem, you can call TaskSystem::Stop(). In this case, the TaskInterface::Interrupt() will be called if the task is still in the waiting queue of the TaskSystem. Finally, the virtual destructor should be overridden so that the derived class can be deleted properly in polymorphism.

    Here is the implementation of TaskSystem:
        template<typename TaskReturnType>
        class TaskSystem final
        {
                typedef std::shared_ptr< TaskInterface<TaskReturnType> > TaskPtr;

                public:
                        void Submit(const TaskPtr& taskPtr_);

                        void Start(size_t numberForProcessors = std::thread::hardware_concurrency() );

                        void Stop(void);

                        TaskSystem() : taskQueue(), listOfThreads(), shouldStop(false) {}
                        ~TaskSystem();
                private:
                        ThreadSafeQueue< TaskPtr > taskQueue;
                        std::vector<std::thread> listOfThreads;
                        std::atomic<bool> shouldStop;

                        // private functions
                        void WorkerThread(void);
        };

        // Implementation of TaskSystem
        template<typename TaskReturnType>
        void TaskSystem<TaskReturnType>::Submit(const TaskPtr& task_)
        {
                this->taskQueue.Push( task_ );
        }

        template<typename TaskReturnType>
        void TaskSystem<TaskReturnType>::Start(size_t numberForProcessors_)
        {
                try
                {
                        for(size_t i=0; i < numberForProcessors_; ++i)
                        {
                                this->listOfThreads.push_back(
                                                                std::thread(&TaskSystem::WorkerThread,
                                                                            this)
                                                             );
                        }
                }
                catch(...)
                {
                        this->shouldStop.store(true);
                        throw;
                }
        }

        template<typename TaskReturnType>
        void TaskSystem<TaskReturnType>::WorkerThread(void)
        {
                while(not this->shouldStop.load())
                {
                        try
                        {
                                TaskPtr taskPtr = *(this->taskQueue.TryPop());
                                taskPtr->Run();
                        }
                        catch(const QueueEmptyException&)
                        {
                                std::this_thread::yield();
                        }
                }
        }

        template<typename TaskReturnType>
        void TaskSystem<TaskReturnType>::Stop(void)
        {
                this->shouldStop.store(true);

                while(not this->taskQueue.IsEmpty() )
                {
                        try
                        {
                                TaskPtr taskPtr = *(this->taskQueue.TryPop());
                                taskPtr->Interrupt();
                        }
                        catch(...)
                        {
                                std::this_thread::yield();
                        }
                }
        }
        template<typename TaskReturnType>
        TaskSystem<TaskReturnType>::~TaskSystem()
        {
                this->shouldStop.store(true);

                for(size_t i=0; i < this->listOfThreads.size(); ++i)
                {
                        if ( this->listOfThreads[i].joinable() )
                                this->listOfThreads[i].join();
                }
        }

};


One can see that when the TaskSystem::Start() is called, TaskSystem will spawn threads with its default value equal to the hardware processors. Each thread runs function TaskSystem::WorkerThread() which will try to pop a task from ThreadSafeQueue (see "C++ Concurrency In Action"), and run that task.


Dividing data

   There're two kinds of situation that the data are divided:

1. Dividing data into chunks and each chunk is processed by one thread. For example, you have a list of data that need to be summed up. Suppose that you have four processors, you can divide the data into four groups. Then, you can define a Task that contained a group of data, and override the TaskInterface::Run() to summed up the data. In this case, dividing data is easy and is the ideal way to process the data in parallel.


2. Dividing data recursively: For the algorithms that use Divide-and-Conquer belong to this category. In this case, the TaskSystem (or, the ThreadPool) often get into trouble because of the absent of the Task-Based mutex and the incapable to perform 'Context Switch' between the tasks. This will be discussed in the next section.


Example: Parallel Merge Sort

The pseudocode of parallel merge sort is shown as follows:
ListType ParallelMergeSort(ListType inputList)
{
    ListType leftHalfList, rightHalfList = inputList.splitInHalf();
    spawn ParallelMergeSort(leftHalfList);
    spawn ParallelMergeSort(rightHalfList);

    sync;
    ListType result = Merge(leftHalfList, rightHalfList);
    return result;
}
    The ParallelMergeSort() first split the input list, then spawn two thread to process each half lists, wait for their result, and finally, Merge() the two half lists.
    However, this may yield dead lock if there is no available thread to run the two spawned tasks: The parent task is waiting for the two spawned tasks. The two child tasks, however, has no available thread to process their data. And since there's no 'Context Switch' for  task, there's no way to take the parent task off and run the two child tasks. Finally, dead lock happen.
    In the following, I try to make an another approach to the parallel merge sort by using following strategies:
1. Use single thread to do the recursive call.
2. Submit the Merge-part into TaskSystem to run in parallel.
The Code is shown below:
        template<typename ListType>
        future<ListType> ParallelMergeSort(ListType&& inputList_, TaskSystem<ListType>& taskSystem)
        {
                size_t numberOfElements = inputList_.size();

                if (numberOfElements > 2)
                {
                        typename ListType::iterator middlePoint = inputList_.begin();
                        std::advance(middlePoint, numberOfElements/2);

                        ListType leftList;
                        leftList.splice(leftList.begin(),
                                        inputList_, inputList_.begin(), middlePoint);
                        ListType rightList;
                        rightList.splice(rightList.begin(),
                                         inputList_, inputList_.begin(), inputList_.end());

                        future<ListType> leftSortedResult = ParallelMergeSort( std::move(leftList), taskSystem);
                        future<ListType>> rightSortedResult = ParallelMergeSort( std::move(rightList), taskSystem);

                        MergeTask<ListType> mergeTask( std::move(leftSortedResult), std::move(rightSortedResult) );
                        future<ListType> finalResult = mergeTask.GetResult();
                        taskSystem.Submit( std::make_shared< MergeTask<ListType> >(std::move(mergeTask)) );

                        return finalResult;
                }
                else if (numberOfElements == 2)
                {
                        ListType result;
                        result.splice( result.begin(), inputList_, inputList_.begin() );
                        if ( (*result.begin()) <= (*inputList_.begin()) )
                        {
                                result.splice(result.end(), inputList_, inputList_.begin());
                        }
                        else
                        {
                                result.splice(result.begin(), inputList_, inputList_.begin());
                        }

                        std::promise<ListType> resultHolder;
                        resultHolder.set_value( std::move(result) );

                        return resultHolder.get_future();
                }
                else
                {
                        std::promise<ListType> resultHolder;
                        resultHolder.set_value( std::move(inputList_) );

                        return resultHolder.get_future();
                }

        }


   This function takes two arguments: the first arguments required the user to move the std::List object to it (the '&&' is the Move semantics which can reserve the time to copy object), and the second is the reference to TaskSystem (where the merge tasks can be submitted to). The return value is std::future, which contained the sorted result.
    Inside the function, if the number of list elements > 2, it split the list by half and call the ParallelMergeSort() recursively till the list elements <=2. When the number of list elements ==2, it sort the element with ease, then return the result that wrapped by std::future. After finish the right and left recursive call, the function create a MergeTask and submit it to TaskSystem. The MergeTask then merge the two lists in parallel. Note that when I declare the ListType::iterator middlePoint, I add "typename" before the declaration since the "iterator" is depend on the template parameter "ListType" (see Effective C++ 3rd, Item 42).

   The MergeTask is implement as follows:
        template<typename ListType>
        class MergeTask : public TaskInterface<ListType>
        {
                public:
                        virtual void Run() override
                        {

                                ListType result;

                                ListType leftList = this->leftListHolder.get();
                                ListType rightList = this->rightListHolder.get();

                                while( (not leftList.empty())||(not rightList.empty() ) )
                                {
                                        if( *(leftList.begin()) <= *(rightList.begin()) )
                                        {
                                                result.splice(result.end(), leftList, leftList.begin() );
                                        }
                                        else
                                        {
                                                result.splice(result.end(), rightList, rightList.begin() );
                                        }

                                        if (leftList.empty())
                                        {
                                                result.splice(result.end(), rightList);
                                                break;
                                        }
                                        else if (rightList.empty())
                                        {
                                                result.splice(result.end(), leftList);
                                                break;
                                        }
                                }
                                this->resultHolder.set_value( std::move(result) );
                        }

                        virtual future<ListType> GetResult() override
                        {
                                return this->resultHolder.get_future();
                        }

                        virtual void Interrupt() override
                        {
                                TaskInterruptException interruptException;
                                this->resultHolder.set_exception( std::make_exception_ptr(interruptException) );
                        }

                        // Constructors
                        MergeTask(future<ListType>&& leftListHolder_, future<ListType>&& rightListHolder_)
                                : resultHolder(),
                                  leftListHolder( std::move(leftListHolder_) ),
                                  rightListHolder( std::move(rightListHolder_) )
                        {
                        }
                        MergeTask(MergeTask&& other_)
                                : resultHolder( std::move(other_.resultHolder) ),
                                  leftListHolder( std::move(other_.leftListHolder) ),
                                  rightListHolder( std::move(other_.rightListHolder) )
                        {
                        }

                        MergeTask(const MergeTask&) = delete;

                        virtual ~MergeTask() {};

                private:
                        std::promise<ListType> resultHolder;
                        future<ListType> leftListHolder;
                        future<ListType> rightListHolder;
        }; // End of class

    In MergeTask, the whole Merge job is define in Run(). This task should be initialized by given two std::future that represent the left-half-list and right-half-list, respectively. When this task is about to merge, it synchronize the two half lists by calling std::future::get(). The calculation result can be obtained from calling MergeTask::GetResult() and the caller will get a std::future which can be synchronized latter.
    This class also use std::promise, which can be image as a summon circle between the caller thread and the calculation thread. Once the calculation thread finish its calculation, it will call std::promise::set_value(), then the result will be transport to the std::future (which can be obtained by calling std::promise::get_future()) in the caller thread.

   The overall procedure to run parallel merge sort is shown as below:
int main()
{
        TaskSystem<ListType> taskSystem;
        taskSystem.Start();

        future<ListType> resultHolder = ParallelMergeSort( std::move(listToBeSorted), taskSystem );
        ListType result = std::move( resultHolder.get() );

        return 0;
}

Result

    Under the above approximation, calling the ParallelMergeSort() will not yield dead lock. However, the efficiency of such ParallelMergeSort() is even slower than the serial one. This may because of nature of the Divide-and-Conquer algorithms that the parent task (the task who spawn other tasks) should wait for its child tasks finished so that it can start to work. Moreover, the result of the child task should also be moved to its parent task which also harshly effect the performance (i.e. the Cache-Ping-Pong).

Conclusion

    This article is temp to implement the TaskSystem with some limitations. In the lower half of this article, I give a example that use TaskSystem to perform parallel merge sort. Although the TaskSystem seems not improve the performance in such approximation, it may get better performance if we don't use the algorithm that divided data recursively.
 
2016.06.01
Joshua P. R. Pan

2016年1月29日 星期五

Unity: How to Serialize Dictionary

Background

    Change Language version of game is often pain in the ass, since each UI image and Audio clips should also be changed. Somebody use subversion (to treat different language version as different branches) to solve this problem. However, it might be inconvenient if you change language version very often.
    Instead, we use Data Center to keep the reference to each UI assets. This Data Center record a Key-Value-Pair in which the Key is the language-independent name of a certain UI, while the Value is the UI Prefab (which is language-dependent, since different language version can have different assets) of that UI.  In the game, if someone want to use that UI, he could send the key (the language-independent name of that UI) to Data Center, and ask for that Prefab. Finally, you can create different Data Center for different language version, and each Data Center can have the same Key while the relative Value different.
   For example, the following figure shows the Data Center for Chinese version.  The key (left-hand-side) "WarningPagePanel" will be universal for different language version Data Centers (so that you don't need to change the images in each scene when you want to change language version), and the value (right-hand-side) is the Chinese version prefab for "WarningPagePanel" (and for Chinese prefab, we have "_CN" in the suffix).
If we want to show some UI in the game, we can stuff the key to a certain script (we call DynamicLoadableUI) which can take the key to get the UI prefab from UI Data Center when we edit the scene.

   To implement such Data Center, I need a Serializable Dictionary that can stuff key-value in and can serialize its data into disk. However, Unity does not provide such Serializable Dictionary. This is what is article aiming for.

Solution

    At first, here is a solution posted by christophfranke123 .  When I implement the Serializable Dictionary by this method, however, I will get "IndexOutOfRangeException" if there're too many Key-Value-Pairs (13 in our case) and I want to add new pair.  I found this might due to the dictionary provide by C# is not thread safe and Unity may use different thread to modify and display the dictionary.  Thus I modify the SerializableDictionary provide by christophfranke123 as below:
[Serializable]
public abstract class SerializableDictionary : ISerializationCallbackReceiver
{
    private System.Object mutexForDictionary = new System.Object();
    private Dictionary dictionary = new Dictionary();

    [SerializeField] private List listOfKeys = new List();
    [SerializeField] private List listOfValues = new List();

#region Serialization Related
    public void OnBeforeSerialize()
    {
        lock (this.mutexForDictionary)
        {
            this.listOfKeys.Clear();
            this.listOfValues.Clear();

            foreach (KeyValuePair eachPair in this.dictionary)
            {
                this.listOfKeys.Add(eachPair.Key);
                this.listOfValues.Add(eachPair.Value);
            }
        }
    }

    public void OnAfterDeserialize()
    {
        lock (this.mutexForDictionary)
        {

            this.dictionary.Clear();
            checkIfKeyAndValueValid();

            for (int i = 0; i < this.listOfKeys.Count; ++i)
            {
                this.dictionary.Add(this.listOfKeys[i], this.listOfValues[i]);
            }
        }
    }
#endregion

#region Dictionary Interface
    public void Add(K _key, V _value)
    {
        lock (this.mutexForDictionary)
        {
            this.dictionary.Add(_key, _value);
        }
    }
    public V this[K _key]
    {
        get 
        {
            lock (this.mutexForDictionary)
            {
                return this.dictionary[_key];
            }
        }
        set 
        {
            lock (this.mutexForDictionary)
            {
                this.dictionary[_key] = value;
            }
        }
    }
    public void Remove(K _key)
    {
        lock (this.mutexForDictionary)
        {
            this.dictionary.Remove(_key);
        }
    }
    public KeyValuePair ElementAt(int _elementIndex)
    {
        lock (this.mutexForDictionary)
        {
            return this.dictionary.ElementAt(_elementIndex);
        }
    }
    public int Count
    {
        get
        {
            lock (this.mutexForDictionary)
            {
                return this.dictionary.Count;
            }
        }
    }

#endregion

    private void checkIfKeyAndValueValid()
    {
        int numberOfKeys = this.listOfKeys.Count;
    
&nbsp &nbsp &nbsp &nbsp int numberOfValues = this.listOfValues.Count;

        if (numberOfKeys != numberOfValues)
        {
            throw new System.ArgumentException("(nKey, nValue) = ("
                                        + numberOfKeys.ToString() + ", " 
                                        + numberOfValues.ToString() + ") are NOT Equal!");
        }
    }
}//End of class


Note

   If you want to customize the Editor for SerializableDictionary (such as what I did in UI_DataCenter), you should note that if you edit of SerializableDictionary (such as drag a new GameObject to its inspector), Unity will not be aware of that. When you leave the scene, Unity will not warn you to save scene after change. Therefore, you might find nothing is record when you enter that scene in the next time. Also, even if you save scene after you change the SerializableDictionary (by press "Ctrl+S", or by "File->Save Scene"), Unity will not actually save that scene (since it does not notice that something is changed).
   To solve this, you should call "EditorApplication.SaveScene();" in the same way as you call the "EditorUtility.SetDirty(this.target);":
 [CustomEditor(typeof(UI_DataCenter))]
 public class UI_DataCenterEditor : Editor
 {
   public override void OnInspectorGUI()
   {
      GUI.changed = false;

      DisplayEachElementOfSelectedDictionary();
      DisplayNewDictionaryElementCreatePanel();

      if (GUI.changed)
      {
         EditorUtility.SetDirty(this.target);
         EditorApplication.SaveScene();
      }

   }
 }


2015年7月27日 星期一

How to Access Android Camera in Unity (III): Customized camera plugin with preview window and UI on it

Overview

   This article will continue the last article and add functionalities such as the camera preview window and buttons to allow user to adjust camera parameters.
  When Unity call this plugin, instead of take a snapshot and leave, the process will stay in the Camera Setting (unless you press the "Return" button so that it'll return to game),  as shown below. In this moment, Unity is temporarily blocked: You can't hear any game sound (unless you invoke it by the android API here), or running game in the background.


Solution


1. At first we need to add one more function "DisplayCameraSettingActivity()" in AndroidCameraAPI.cs, so that it would like:
/*
 * This Class Call the Android Code to Take Picture.
 * Note: there should be a AndroidCameraAPI.jar in \Assets\Plugins\Android
 */
public class AndroidCameraAPI : MonoBehaviour
{
    private AndroidJavaObject androidCameraActivity;

    public void Awake()
    {
        AndroidJavaClass unity = new AndroidJavaClass("com.unity3d.player.UnityPlayer");
        this.androidCameraActivity = unity.GetStatic<AndroidJavaObject>("currentActivity");
    }

    public void TakePhotoFromAndroidAPI(string _pathToSavePhoto, string _fileNameOfSavedPhoto)
    {
        this.androidCameraActivity.Call("TakePhoto",
                                        _pathToSavePhoto, _fileNameOfSavedPhoto+".jpg");
    }

    public void DisplayCameraSettingActivity()
    {
        this.androidCameraActivity.Call("DisplayCameraSettingActivity");
    }
}


2. In the Entrance of Android API (the MainActivity.java):
import android.content.Intent;
import android.hardware.Camera;
import android.os.Bundle;
import android.util.Log;

import com.unity3d.player.UnityPlayerActivity;

public class MainActivity extends UnityPlayerActivity
{
    private Camera androidCamera = null;
    private Camera.Parameters userDefinedCameraParameters = null;

    @Override
    public void onCreate(Bundle _savedInstanceState)
    {
        super.onCreate(_savedInstanceState);

        openCameraSafely();
        setupCameraWithDefaultParameters();
    }
    private void openCameraSafely()
    {
        Log.i("Unity", "Open Camera Safely...");
        try
        {
            this.androidCamera = Camera.open();
        }
        catch(Exception cameraIOException)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Cannot Connect to Camera,"
                                                + " please Check connection...\n"
                                                + "\tIf this doesn't work, please"
                                                + " Replug the Camera or Reboot this Machine.");

            this.finish();
        }
        Log.i("Unity", "Open Camera Success!");
    }
    private void setupCameraWithDefaultParameters()
    {
        try
        {
            this.userDefinedCameraParameters = this.androidCamera.getParameters();
            this.userDefinedCameraParameters.setExposureCompensation(CameraDataCenter.userDefinedCameraExposureLevel);
            this.userDefinedCameraParameters.setZoom(CameraDataCenter.userDefinedCameraZoomLevel);
            this.userDefinedCameraParameters.setPictureSize(CameraDataCenter.PHOTO_WIDTH,
                                                            CameraDataCenter.PHOTO_HEIGHT);
            this.androidCamera.setParameters(this.userDefinedCameraParameters);
        }
        catch(Exception exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Can't get CameraParameters,"
                                                +" which means the camera might in bad status."
                                                +" Do you access the camera with multithread?");
        }
    }

    public void DisplayCameraSettingActivity()
    {
        Log.i("Unity", "Go to Camera Settings...");
        Intent intentOfCameraSetting = new Intent(this, CameraSettingActivity.class);
        this.androidCamera.release();
        startActivityForResult(intentOfCameraSetting,
                                CameraDataCenter.CAMERA_SETTING_REQUEST_CODE);
    }

    protected void onActivityResult(int _requestCode, int _resultCode, Intent _cameraSettingIntent)
    {
        Log.i("Unity", "MainActivity.onActivityResult().");
        if( (_requestCode == CameraDataCenter.CAMERA_SETTING_REQUEST_CODE)
            &&(_resultCode == RESULT_OK) )
        {
            this.userDefinedCameraParameters.setExposureCompensation(CameraDataCenter.userDefinedCameraExposureLevel);
            this.userDefinedCameraParameters.setZoom(CameraDataCenter.userDefinedCameraZoomLevel);
        }
        this.openCameraSafely();
    }


    public void TakePhoto(final String _targetPathToSavePhoto,
                          final String _targetPhotoFileName)
    {
        Log.i("Unity", "Take Photo...");
        if(this.userDefinedCameraParameters != null)
            this.androidCamera.setParameters(this.userDefinedCameraParameters);
        this.androidCamera.startPreview();

            Camera.PictureCallback savePictureCallBack = new SavePictureCallBack(_targetPathToSavePhoto, _targetPhotoFileName);
            this.androidCamera.takePicture(null, null, savePictureCallBack);

            Log.i("Unity", "Take Photo Success!");
    }

    @Override
    public void onDestroy()
    {
        Log.i("Unity", "CameraActivity is Destroyed!");
        if(this.androidCamera != null)
            this.androidCamera.release();

        super.onDestroy();
    }

}

    You can see that when you call DisplayCameraSettingActivity(), the process will change to CameraSettingActivity which will be demonstrate bellow.
    Note that When you move to another Activity, you should release the lock of android.camera by camera.release() since only one activity can hold the lock of android.camera.
   Also note that when the CameraSettingActivity return (when the user hit the "Return" button on the screen), the function onActivityResult() will be called. That is the time that we require the lock of android.camera back (so that the TakePhoto() can be called latter in Unity). Then the process will return to Unity and continue the game.

3. The CameraSettingActivity.java is shown below:
public class CameraSettingActivity extends Activity
{
    private Camera androidCamera;
    private Camera.Parameters userDefinedCameraParameters = null;
    private CameraPreviewer cameraPreviewer;
    private FrameLayout cameraPreviewFrame;

    private LinearLayout linearLayout;
    private TextView exposureLevelText;
    private TextView zoomLevelText;
    private Button returnButton;
    private final float UI_TEXT_SIZE = 32f;


    @Override
    protected void onCreate(Bundle _savedInstanceState)
    {
        super.onCreate(_savedInstanceState);

        initializeLayoutSetting();

        openCameraSafely();
        setupCameraWithDefaultParameters();
        initializeCameraPreview();

        createReturnButton();
        CreateExposureInspector();
        CreateZoomLevelInspector();
    }
    private void initializeLayoutSetting()
    {
        DisplayMetrics displayedScreen = new DisplayMetrics();
        this.getWindowManager().getDefaultDisplay().getMetrics(displayedScreen);

        this.requestWindowFeature(Window.FEATURE_NO_TITLE);
        this.getWindow().setFlags(WindowManager.LayoutParams.FLAG_FULLSCREEN,
                                  WindowManager.LayoutParams.FLAG_FULLSCREEN);

        this.linearLayout = new LinearLayout(this);
        LayoutParams parametersOfLinearLayout = new LayoutParams(LayoutParams.MATCH_PARENT,
                                                                 LayoutParams.MATCH_PARENT);

        setContentView(this.linearLayout, parametersOfLinearLayout);
    }
    private void openCameraSafely()
    {
        try
        {
            this.androidCamera = Camera.open();
        }
        catch(Exception cameraIOException)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Cannot Connect to Camera,"
                                                + " please Check connection...\n"
                                                + "\tIf this doesn't work, please"
                                                + " Replug the Camera or Reboot this Machine.");

            this.finish();
        }
    }

    /*
     * UI Related...
     */
    private void createReturnButton()
    {
        this.returnButton = new Button(this);
        this.returnButton.setText("Return");
        this.returnButton.setTextSize(UI_TEXT_SIZE);
        this.returnButton.setOnClickListener(
                new Button.OnClickListener()
                {
                    @Override
                    public void onClick(View _view)
                    {
                        OnReturnButtonClick(_view);
                    }
                }
        );
        this.returnButton.setX(100);
        this.returnButton.setY(600);
        addContentView( this.returnButton, new LayoutParams(150, 75) );
    }

    private void CreateExposureInspector()
    {
        createIncreaseExposureButton(350, 75, 75, 65);
        createCurrentExposureText(500, 85, 400, 70);
        createDecreaseExposureButton(850, 75, 75, 65);
    }
    private void createIncreaseExposureButton(int _left, int _top, int _width, int _height)
    {
        Button increaseExposureButton = new Button(this);
        increaseExposureButton.setText("+");
        increaseExposureButton.setTextSize(UI_TEXT_SIZE);
        increaseExposureButton.setOnClickListener(
                new Button.OnClickListener()
                {
                    @Override
                    public void onClick(View _view)
                    {
                        OnIncreaseExposureButtonClick(_view);
                    }
                }
        );
        increaseExposureButton.setX(_left);
        increaseExposureButton.setY(_top);
        addContentView( increaseExposureButton, new LayoutParams(_width, _height) );
    }
    private void createCurrentExposureText(int _left, int _top, int _width, int _height)
    {
        this.exposureLevelText = new TextView(this);
        this.exposureLevelText.setTextSize(UI_TEXT_SIZE);
        updateExposureLevelTexts();
        this.exposureLevelText.setX(_left);
        this.exposureLevelText.setY(_top);
        addContentView(this.exposureLevelText, new LayoutParams(_width, _height));
    }
    private void createDecreaseExposureButton(int _left, int _top, int _width, int _height)
    {
        Button decreaseExposureButton = new Button(this);
        decreaseExposureButton.setText("-");
        decreaseExposureButton.setTextSize(UI_TEXT_SIZE);
        decreaseExposureButton.setOnClickListener(
                new Button.OnClickListener()
                {
                    @Override
                    public void onClick(View _view)
                    {
                        OnDecreaseExposureButtonClick(_view);
                    }
                }
        );
        decreaseExposureButton.setX(_left);
        decreaseExposureButton.setY(_top);
        addContentView( decreaseExposureButton, new LayoutParams(_width, _height) );
    }
    private void updateExposureLevelTexts()
    {
        int currentExposureLevel = CameraDataCenter.userDefinedCameraExposureLevel;

        if( currentExposureLevel > 0)
            this.exposureLevelText.setText("Exposure Level:  +"+currentExposureLevel);
        else
            this.exposureLevelText.setText("Exposure Level:  "+currentExposureLevel);
    }

    private void CreateZoomLevelInspector()
    {
        createIncreaseZoomLevelButton(350, 150, 75, 65);
        createCurrentZoomLevelText(500, 160, 400, 70);
        createDecreaseZoomLevelButton(850, 150, 75, 65);
    }
    private void createIncreaseZoomLevelButton(int _left, int _top, int _width, int _height)
    {
        Button increaseZoomLevelButton = new Button(this);
        increaseZoomLevelButton.setText("+");
        increaseZoomLevelButton.setTextSize(UI_TEXT_SIZE);
        increaseZoomLevelButton.setOnClickListener(
                new Button.OnClickListener()
                {
                    @Override
                    public void onClick(View _view)
                    {
                        OnIncreaseZoomLeveleButtonClick(_view);
                    }
                }
        );
        increaseZoomLevelButton.setX(_left);
        increaseZoomLevelButton.setY(_top);
        addContentView( increaseZoomLevelButton, new LayoutParams(_width, _height) );
    }
    private void createCurrentZoomLevelText(int _left, int _top, int _width, int _height)
    {
        this.zoomLevelText = new TextView(this);
        this.zoomLevelText.setTextSize(UI_TEXT_SIZE);
        updateZoomLevelTexts();
        this.zoomLevelText.setX(_left);
        this.zoomLevelText.setY(_top);
        addContentView(this.zoomLevelText, new LayoutParams(_width, _height));
    }
    private void createDecreaseZoomLevelButton(int _left, int _top, int _width, int _height)
    {
        Button decreaseZoomLevelButton = new Button(this);
        decreaseZoomLevelButton.setText("-");
        decreaseZoomLevelButton.setTextSize(UI_TEXT_SIZE);
        decreaseZoomLevelButton.setOnClickListener(
                new Button.OnClickListener()
                {
                    @Override
                    public void onClick(View _view)
                    {
                        OnDecreaseZoomLevelButtonClick(_view);
                    }
                }
        );
        decreaseZoomLevelButton.setX(_left);
        decreaseZoomLevelButton.setY(_top);
        addContentView( decreaseZoomLevelButton, new LayoutParams(_width, _height) );
    }
    private void updateZoomLevelTexts()
    {
        int currentZoomLevel = CameraDataCenter.userDefinedCameraZoomLevel;

        if( currentZoomLevel > 0)
            this.zoomLevelText.setText("Zoom Level:  +"+currentZoomLevel);
        else
            this.zoomLevelText.setText("Zoom Level:  "+currentZoomLevel);
    }

    /*
     * Camera Settings Related...
     */
    private void initializeCameraPreview()
    {
        this.cameraPreviewer = new CameraPreviewer(this, this.androidCamera);

        this.cameraPreviewFrame = new FrameLayout(this);
        addContentView(this.cameraPreviewFrame,
                       new LayoutParams(ViewGroup.LayoutParams.FILL_PARENT, LayoutParams.FILL_PARENT)
                      );
        this.cameraPreviewFrame.addView(this.cameraPreviewer);
    }
    private void setupCameraWithDefaultParameters()
    {
        try
        {
            this.userDefinedCameraParameters = this.androidCamera.getParameters();
            this.userDefinedCameraParameters.setPictureSize(CameraDataCenter.PHOTO_WIDTH,
                                                            CameraDataCenter.PHOTO_HEIGHT);
            updateCameraExposureSettings(CameraDataCenter.userDefinedCameraExposureLevel);
            updateCameraZoomSettings(CameraDataCenter.userDefinedCameraZoomLevel);
        }
        catch(Exception exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                 "Can't get CameraParameters,"
                                                +" which means the camera might in bad status."
                                                +" Do you access the camera with multithread?");
        }
    }
    private void updateCameraExposureSettings(int _userRequiredExposure)
    {
        try
        {
            CameraDataCenter.userDefinedCameraExposureLevel = _userRequiredExposure;
            this.userDefinedCameraParameters.setExposureCompensation(_userRequiredExposure);
            this.androidCamera.setParameters(userDefinedCameraParameters);
        }
        catch(Exception exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Can't Set CameraParameters,"
                                                +"  Are there Invalid Camera Settings "
                                                +"(such as Invalid Picture Size, Zoom Level"
                                                +" or Exposure Level)?");
        }
    }
    private void updateCameraZoomSettings(int _userDefinedZoomLevel)
    {
        try
        {
            CameraDataCenter.userDefinedCameraZoomLevel = _userDefinedZoomLevel;
            this.userDefinedCameraParameters.setZoom(_userDefinedZoomLevel);
            this.androidCamera.setParameters(userDefinedCameraParameters);
        }
        catch(Exception exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Can't Set CameraParameters,"
                                                +"  Are there Invalid Camera Settings "
                                                +"(such as Invalid Picture Size, Zoom Level"
                                                +" or Exposure Level)?");
        }
    }

    /*
     * Following is the Call Back Functions for Button Clicked.
     */
    public void OnIncreaseExposureButtonClick(View _increaseExposureButton)
    {
        int currentExposure = this.userDefinedCameraParameters.getExposureCompensation();
        ++currentExposure;
        int maxExposure = this.userDefinedCameraParameters.getMaxExposureCompensation();
        if( currentExposure > maxExposure )
            currentExposure = maxExposure;
        updateCameraExposureSettings(currentExposure);
        updateExposureLevelTexts();
    }
    public void OnDecreaseExposureButtonClick(View _decreaseExposureButton)
    {
        int currentExposure = this.userDefinedCameraParameters.getExposureCompensation();
        --currentExposure;
        int minExposure = this.userDefinedCameraParameters.getMinExposureCompensation();
        if( currentExposure < minExposure)
            currentExposure = minExposure;
        updateCameraExposureSettings(currentExposure);
        updateExposureLevelTexts();
    }
    public void OnIncreaseZoomLeveleButtonClick(View _increaseZoomButton)
    {
        int currentZoomLevel = this.userDefinedCameraParameters.getZoom();
        ++currentZoomLevel;
        int maxZoomLevel = this.userDefinedCameraParameters.getMaxZoom();
        if( currentZoomLevel > maxZoomLevel )
            currentZoomLevel = maxZoomLevel;
        updateCameraZoomSettings(currentZoomLevel);
        updateZoomLevelTexts();
    }
    public void OnDecreaseZoomLevelButtonClick(View _decreaseZoomeButton)
    {
        int currentZoomLevel = this.userDefinedCameraParameters.getZoom();
        --currentZoomLevel;
        int minZoomLevel = 0;
        if( currentZoomLevel < minZoomLevel)
            currentZoomLevel = minZoomLevel;
        updateCameraZoomSettings(currentZoomLevel);
        updateZoomLevelTexts();
    }

    public void OnReturnButtonClick(View _returnButton)
    {
        this.androidCamera.stopPreview();

        Intent returnIntent = new Intent();
        setResult(RESULT_OK, returnIntent);

        Log.i("Unity", "Release Camera...");
        this.androidCamera.release();
        this.finish();
    }

    @Override
    public void onDestroy()
    {
        Log.i("Unity", "CameraActivity is Destroyed!");
        if(this.androidCamera != null)
            this.androidCamera.release();

        super.onDestroy();
    }
}
   You can see that I create the buttons dynamically in onCreate(), instead of using the R.layout (which is the normal way to create UI widget in android), because there're some issue about the missing of  R.layout when the Unity use android plugins. I guess the reason might be that Unity will replace the R.layout itself... And this is the reason that I don't call the
    setContentView(R.layout.activity_main);
in the onCreate() as we normally do when writing "pure" android app.

4. Since you have two Activities now, you should also change your AndroidManifest.xml to:
<?xml version="1.0" encoding="utf-8"?>
<manifest xmlns:android="http://schemas.android.com/apk/res/android"
      package="com.igs.dinosaur"
      android:versionCode="1"
      android:versionName="1.0">
    <uses-sdk android:minSdkVersion="9" />
 
 <uses-permission android:name="android.permission.CAMERA" />
 <uses-feature android:name="android.hardware.camera" />
 <uses-feature android:name="android.hardware.camera.autofocus" />
 <uses-permission android:name="android.permission.WRITE_EXTERNAL_STORAGE"/>
 
    <application
  android:icon="@drawable/app_icon"
  android:label="@string/app_name"
  android:debuggable="true">
  
        <activity android:name=".MainActivity"
                  android:label="@string/app_name">
            <intent-filter>
                <action android:name="android.intent.action.MAIN" />
                <category android:name="android.intent.category.LAUNCHER" />
            </intent-filter>
        </activity>
  
  <activity android:name=".CameraSettingActivity">
  </activity>
  
    </application>
</manifest>

5. Finally, here is the CameraPreviewer that will be called by the CameraSettingActivity:
public class CameraPreviewer extends SurfaceView
                            implements SurfaceHolder.Callback
{
    private SurfaceHolder displayedSurface;
    private Camera currentCamera;

    public CameraPreviewer(Context _cameraContext, Camera _camera)
    {
        super(_cameraContext);
        this.currentCamera = _camera;
        this.displayedSurface = this.getHolder();
        this.displayedSurface.addCallback(this);

        //Following line might be required if you use the early version of android
        this.displayedSurface.setType(SurfaceHolder.SURFACE_TYPE_PUSH_BUFFERS);
    }

    @Override
    public void surfaceCreated(SurfaceHolder _surfaceHolder)
    {
        try
        {
            this.currentCamera.setPreviewDisplay(_surfaceHolder);
            this.currentCamera.startPreview();
        }
        catch (IOException exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                 "Camera Preview failed, this might due to"
                                                 +" the SurfaceHolder cannot be obtained...");
        }
    }

    @Override
    public void surfaceChanged(SurfaceHolder _surfaceHolder, int _format, int _width, int _height)
    {
        this.Refresh();
    }

    public void Refresh()
    {
        stopPreviewBeforeRefresh();
        restartPreview();
    }
    private void stopPreviewBeforeRefresh()
    {
        try
        {
            this.currentCamera.stopPreview();
        }
        catch(Exception _exception)
        {
            /*
             * This Exception can be Ignore, since it
             * might be no preview before.
             */
        }
    }
    private void restartPreview()
    {
        try
        {
            this.currentCamera.setPreviewDisplay(this.displayedSurface);
            this.currentCamera.startPreview();
        }
        catch (IOException exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                 "Camera Preview failed, this might due to"
                                                 + " the SurfaceHolder cannot be obtained...");
        }
    }

    @Override
    public void surfaceDestroyed(SurfaceHolder _surfaceHolder) {}
}


Result

    Now you can adjust the camera parameters by click the buttons and preview the camera, as shown below.


Conclusion

    Here're the advantages and disadvantages of calling the camera in Android API compare to the Unity API:

Advantages:

     As mention in the last article, you can adjust many camera parameters in android API.

Disadvantages:

    When calling the android API, Unity will temporary stopped. So if you want to play music, display UI or detect IO, you should do it in Android API! You can't rely on the easy-to-use Unity anymore.

2016/6/2 updated:
   We finally solve the Unity temporary stopped problem by using the Android Service. The Service is like running things in another thread, but yet its display can cover the original APP.
   Therefore, we extend the Service that can display camera video. When we want to show the WebCam preview window, we call that Service. And it will display the camera video which will cover the display of our game but yet leave the game still running.
    This solution could also be used to solve the temporary stop problem when you want to apply Unity API to display movie in Android. You can extend the Service to display movie so that the game will still running when the movie is playing.


2015年7月19日 星期日

How to Access Android Camera in Unity (II): Customized android plugin by calling Android API

Overview

     In the last article, I use the Unity default WebCamTexture to read the input from camera device. However, it seems that nearly none of the camera parameters is adjustable.  In this article, I'll show you how to customized the camera by android API and how to invoke it from Unity.


Solution


How to call android plugins in Unity

      If you have no experience of building an android plugin, here is a good tutorial. Note that the "package name" in Android should match the "Bundle ID" in Unity. Also note that if you have upper case in your package name, it would be transferred to lower case automatically when you build the new project. This will result in the mismatch of package name and the Bundle ID. Although there're several websites have mentioned how to change package name, I failed. So it would be better to get it right at the beginning.

How to customize Android Camera

     You can follow the android documents step by step. There're also several examples such as here and here. However, none of them is aimed to build android plugins for Unity. Following will show you how to build customized plugin for Unity.

1. Create a script (AndroidCameraAPI.cs) to call the android plugin in Unity:
/// <summary>
/// This Class Call the Android Code to Take Picture.
/// Note: there should be a AndroidCameraAPI.jar in \Assets\Plugins\Android
/// </summary>
public class AndroidCameraAPI : MonoBehaviour
{
   private AndroidJavaObject androidCameraActivity;

   public void Awake()
   {
      AndroidJavaClass unity = new AndroidJavaClass("com.unity3d.player.UnityPlayer");
      this.androidCameraActivity = unity.GetStatic<AndroidJavaObject>("currentActivity");
   }

   /// <summary>
   /// Note: Only support the "jpg" format, and you should NOT include the File Name Extension. 
   ///   For example, use
   ///   TakePhotoFromAndroidAPI(path, "myImage");
   ///   instead of
   ///   TakePhotoFromAndroidAPI(path, "myImage.jpg");
   /// </summary>
   /// <param name="_pathToSavePhoto"></param>
   /// <param name="_fileNameOfSavedPhoto"></param>
   public void TakePhotoFromAndroidAPI(string _pathToSavePhoto, string _fileNameOfSavedPhoto)
   {
      this.androidCameraActivity.Call("TakePhoto",
                                      _pathToSavePhoto,
                                      _fileNameOfSavedPhoto + ".jpg");
   }
}

2. Now edit the MainActivity.java (which can be thought as the entrance of Android) in AndroidStudio:
import android.content.Intent;
import android.hardware.Camera;
import android.os.Bundle;
import android.util.Log;

import com.unity3d.player.UnityPlayerActivity;

public class MainActivity extends UnityPlayerActivity
{
    private Camera androidCamera = null;
    private Camera.Parameters userDefinedCameraParameters = null;

    @Override
    public void onCreate(Bundle _savedInstanceState)
    {
        super.onCreate(_savedInstanceState);

        openCameraSafely();
        setupCameraWithDefaultParameters();
    }
    private void openCameraSafely()
    {
        Log.i("Unity", "Open Camera Safely...");
        try
        {
            this.androidCamera = Camera.open();
        }
        catch(Exception cameraIOException)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Cannot Connect to Camera,"
                                                + " please Check connection...\n"
                                                + "\tIf this doesn't work, please"
                                                + " Replug the Camera or Reboot this Machine.");

            this.finish();
        }
        Log.i("Unity", "Open Camera Success!");
    }
    private void setupCameraWithDefaultParameters()
    {
        try
        {
            this.userDefinedCameraParameters = this.androidCamera.getParameters();
            this.userDefinedCameraParameters.setExposureCompensation(CameraDataCenter.userDefinedCameraExposureLevel);
            this.userDefinedCameraParameters.setZoom(CameraDataCenter.userDefinedCameraZoomLevel);
            this.userDefinedCameraParameters.setPictureSize(CameraDataCenter.PHOTO_WIDTH,
                                                            CameraDataCenter.PHOTO_HEIGHT);
            this.androidCamera.setParameters(this.userDefinedCameraParameters);
        }
        catch(Exception exception)
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Can't get CameraParameters,"
                                                +" which means the camera might in bad status."
                                                +" Do you access the camera with multithread?");
        }
    }

    public void TakePhoto(final String _targetPathToSavePhoto,
                          final String _targetPhotoFileName)
    {
        Log.i("Unity", "Take Photo...");
        if(this.userDefinedCameraParameters != null)
            this.androidCamera.setParameters(this.userDefinedCameraParameters);
        this.androidCamera.startPreview();

            Camera.PictureCallback savePictureCallBack = new SavePictureCallBack(_targetPathToSavePhoto, _targetPhotoFileName);
            this.androidCamera.takePicture(null, null, savePictureCallBack);

            Log.i("Unity", "Take Photo Success!");
    }

    @Override
    public void onDestroy()
    {
        Log.i("Unity", "CameraActivity is Destroyed!");
        if(this.androidCamera != null)
            this.androidCamera.release();

        super.onDestroy();
    }

}
Note: You should delete the line
    setContentView(R.layout.activity_main);
in onCreate(). The reason will be illustrated in the next article.

3. The CameraDataCenter.java is used to store some camera parameters.
public class CameraDataCenter
{
    public static final int DEFAULT_CAMERA_EXPOSURE_LEVEL = 3;
    public static int userDefinedCameraExposureLevel = DEFAULT_CAMERA_EXPOSURE_LEVEL;

    public static final int DEFAULT_CAMERA_ZOOM_LEVEL = 0;
    public static int userDefinedCameraZoomLevel = DEFAULT_CAMERA_ZOOM_LEVEL;

    public static final int CAMERA_SETTING_REQUEST_CODE = 999;

    public static final int PHOTO_WIDTH = 1280;
    public static final int PHOTO_HEIGHT = 720;
}

4. The SavePictureCallBack.java is a callback for TakePhoto() in MainActivity. And will tell the system how to save the photo you just taken.
import android.hardware.Camera;
import android.util.Log;

import java.io.File;
import java.io.FileOutputStream;
import java.io.IOException;

public class SavePictureCallBack implements Camera.PictureCallback
{
    private String targetPathToSavePhoto;
    private String targetFileNameOfPhoto;

    public SavePictureCallBack(final String _targetPath, final String _targetPhotoFileName)
    {
        this.targetPathToSavePhoto = _targetPath;
        this.targetFileNameOfPhoto = _targetPhotoFileName;
    }

    @Override
    public void onPictureTaken(byte[] _data, Camera _camera)
    {
        File newImageFile = new File(this.targetPathToSavePhoto, this.targetFileNameOfPhoto);
        if( newImageFile != null)
        {
            FileOutputStream fileStream = null;
            try
            {
                fileStream = new FileOutputStream(newImageFile);
                fileStream.write(_data);
                Log.i("Unity", "Save Photo to: " + newImageFile.getPath() + " Success!");
            }
            catch (Exception exception)
            {
                ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                    "Photo is taken, but can't be saved."
                                                    + " If this error keeps happening,"
                                                    + " please Check your Disk Space");
            }
            finally
            {
                CloseFileAndReportExceptionByLog(fileStream);
            }

        }
        else
        {
            ExceptionManager.SaveErrorCodeToFile(ExceptionManager.CAMERA_ERROR_LOG_FILE_NAME,
                                                "Photo is taken, but can't be saved."
                                                + " If this error keeps happening,"
                                                + " please Check your Disk Space");

        }

    }

    public static void CloseFileAndReportExceptionByLog(FileOutputStream _fileToBeClose)
    {
        try
        {
            _fileToBeClose.close();
        }
        catch(IOException exception)
        {
            Log.w("Unity", "Close Image file Failed.");
        }
    }
}

5. Finally, the AndroidManifest.xml:
<?xml version="1.0" encoding="utf-8"?>
<manifest xmlns:android="http://schemas.android.com/apk/res/android"
      package="com.igs.dinosaur"
      android:versionCode="1"
      android:versionName="1.0">
    <uses-sdk android:minSdkVersion="9" />
 
 <uses-permission android:name="android.permission.CAMERA" />
 <uses-feature android:name="android.hardware.camera" />
 <uses-feature android:name="android.hardware.camera.autofocus" />
 <uses-permission android:name="android.permission.WRITE_EXTERNAL_STORAGE"/>
 
    <application
  android:icon="@drawable/app_icon"
  android:label="@string/app_name"
  android:debuggable="true">
  
        <activity android:name=".MainActivity"
                  android:label="@string/app_name">
            <intent-filter>
                <action android:name="android.intent.action.MAIN" />
                <category android:name="android.intent.category.LAUNCHER" />
            </intent-filter>
        </activity>
  
  
    </application>
</manifest>


Result

     If you call the AndroidCameraAPI.TakePhoto() in Unity, it will take a snapshot immediately. The result is shown below. As you can see, after adjust the exposure, the camera  looks better now.


Conclusion

Following list the advantages and disadvantages:

Advantages:

1. You can adjust many parameters provided by android API.
2. The camera will be auto-focus when you take a picture (There'll be no auto-focus if you just take a
    screenshot from the Unity default WebCamTexture).

Disadvantages:

1. Despite the complicated procedure, you can't change the Bundle ID now. Otherwise you should
    also change the package name in AndroidStudio.
2. When you call the Android plugin, the Unity will be temporary paused. In this article, you can't
    feel it because the time for calling android plugin is too soon. In the next article, I will make a
    preview layout for camera and the system will stay in android unless the user press "Return"
    button.  In that situation, the Unity will be paused which means that the Unity can't read any IO
    and stop playing musics when the system go down to android.

2015年7月18日 星期六

How to Access Android Camera in Unity (I): Using Unity WebCamTexture

Overview

    This article will show you how to access Camera in Android device by calling the Unity built-in class: WebCamTexture. This is simply the easiest way to access the native camera.
    However, there're not so much parameters (such as Exposure, Zoom Level) can be adjusted. But if none of those in your concern, WebCamTexture might be the best way to approach. Since you can combine it with other Unity utilities (such as UI, sound) with WebCamTexture easily.
    Moreover, there're many websites have discussed how to use WebCamTexture, but none of them use the new Unity feature UGUI till now, this article will also show you how to combine WebCamTexture with UGUI.

Background

    Our company want to develop a game in a device which use Android as its OS. During the game, the camera in the devices will take some snapshots of the Players' face and print the picture for them as a souvenir.

Solution

Note: This article is original combine WebCamTexture and UI.Image. However, it will create a big array to contain pixels each frame. The game will finally run out of memory. Fortunately, this website suggest the use of UI.RawImage. This article has been updated to use such RawImage.

1. Setup the Unity Editor by following arrangement:
    (1) A parent Game Object "WebCamModule" that has Canvas as its Component.
    (2) A child Game Object "VedioImage" that has RawImage component. The RawImage is used to
          preview the camera.
    (3) Attach the "WebCamModule" Game Object by the following script:
 public class WebCamModule : MonoBehaviour
 {
   private WebCamTexture webCameTexture;
   [SerializeField] private RawImage vedioImage;

   protected void Awake()
   {
    this.webCameTexture = new WebCamTexture(1280, 720);
    this.vedioImage.texture = this.webCameTexture;
   }

   public void Play()
   {
     this.webCameTexture.requestedWidth = 1280;
     this.webCameTexture.requestedHeight = 720;
     this.webCameTexture.Play();
   }
   public void Stop()
   {
     this.webCameTexture.Stop();
   }
   public Texture2D TakePhoto()
   {
    Texture2D photoShot = new Texture2D(this.webCameTexture.width, this.webCameTexture.height);
    photoShot.SetPixels32(this.webCameTexture.GetPixels32());
    photoShot.Apply();

    return photoShot;
   }
 }


    (4) The arrangement of Unity Editor will be:


Result

Build and run in the android device, you will find:
   As you can see, the resulting photo is too dark. This is due to the default exposure of the camera is too low (Unity just use the default camera parameters from devices). This might because we connect the android device with external WebCam. If you use the default camera that has been built-in your android phone, there might be no problem. Since the vendor of your phone may adjust the default parameters of the camera before it has been released...
   So, is there a way to fix this? The answer is no if you want to adjust the exposure by WebCamTexture, since it nearly provide nothing to adjust the camera settings.
    You can however, brighten the photo by some algorithms pixel by pixel. But it might be better if you can adjust the camera parameters directly (by invoke android API). In the next article, I will show you how.

Conclusion

Here are the conclusion of Unity built-in WebCamTexture:

Advantages: 

Easy to setup, and can be combined with UGUI, sounds, or other Unity utilities.

Disadvantages: 

You can not adjust camera parameters such as exposure, zoom level. Moreover, you get the picture just by screen shot, instead of requiring the camera to take picture by some command. This means that the camera will not adjust its focus when you take picture and will finally get a not-so-good photo.

In the next article, I will show you how to access native camera by calling the android camera API.